
Contain and release ping pong balls. WRO Elementary 2015. Part 2
Improving the construction for the World Robotics Olympiad missions. The improvement is in the position of the sensor and the size of the balls container.
- #137
- 12 Dec 2015
Improving the construction for the World Robotics Olympiad missions. The improvement is in the position of the sensor and the size of the balls container.

Бележки за построяването на Петминутен робот.

Опитайте сами да поставите сензор за допир на робота.

DIfferent wheels and tires will result in different behaviour of the robot. That is actually pretty common sense. The real question is what is the influence. Would the robot make smaller deviations if it has smaller wheels or it will make larger deviations? The tires could also be quite dirty or brand new. Or the wheels could be attached in different ways.

In this video tutorial, we would do a few experiments with the coefficients for the Integral compensation. There are actually two coefficients - "c" and "b"

This is a 10 out of 10 tutorial for a 3 missions run. The robot goes out of base and accomplishes 3 missions in a single run. It demonstrates the consistency and reliability of the robot and its program that uses sensors.

The challenge for this video is to program a menu that is controlled from the LEGO Mindstorms EV3 brick screen.

For the current specific example we need two parts - the diode and the controller. In this episode we would show you which part is the controller, which are the jumpers and finally we would choose a diode.
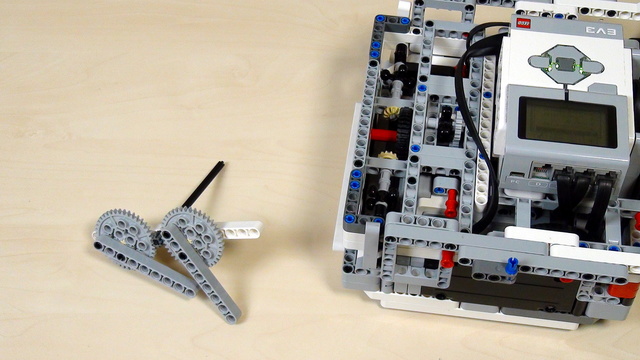
Time to lift the robot. The first approach is by using the 40 teeth gear wheels that come with the LEGO Mindstorms EV3 and NXT robotics sets.
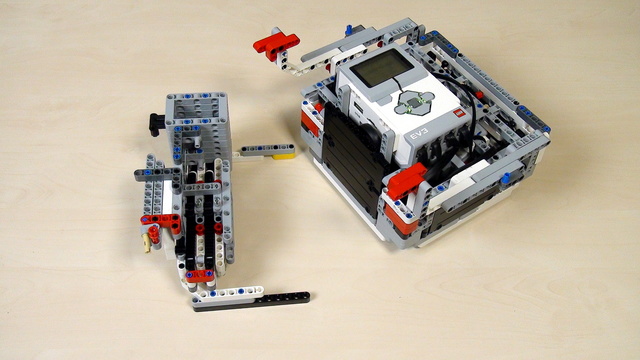
The next step of lifting a robot to a mission model is to try to use a rack.

In this tutorial, we would drive the scissors mechanism and there are a number of rules that we must follow

Construct two legs for both sides of the robot. The task for this video is to attach this two legs on both sides and to build a system of gears and axles that power those legs.

In this video we discuss the durability of the construction of LEGO robots and how do we make them more durable.

We calculate the number of rotatios when a gear system is involved. The driving wheel will have to do a number of rotations for the driven wheel to rotate to a desired number of degrees. In our specific case when the driven gear wheel is rotate to about 90 degrees the legs will lift the robot.
