
За преподавателя: Как да давате задачи за движение
Какво трябва да знае всеки преподавател, когато дава задачи на ученици.
- #372
- 04 Feb 2017
Какво трябва да знае всеки преподавател, когато дава задачи на ученици.

We got the speed of rotations of the motor in Radians per second. Let's calculate the value for the speed of the whole system. We calculate that the wheels are rotating with 375 radians per second. Which is impressive and quite fast for this system. From this speed, knowing the inertia mass we can calculate how much energy is the system accumulating.

In this video tutorial we demonstrate how to accomplish M09 of FIRST LEGO League 2023-2024 MASTERPIECE Challenge. The robot is Chain Monster - a LEGO Education SPIKE Prime robot. It pulls the mission model and precisely positions it in the designated area. An interesting aspect is that the robot must rotate to position the loop correctly, so pay close attention when programming it.

So far we know how to make a turn in an arc, just like the real cars do.
Today we will see what other options our robots have for turning.

Бележки за построяването на Петминутен робот.

Ще научим как да свързваме и да откачваме LEGO кабелите и в кои мотори трябва да свързваме двигателите.

Най-добрият начин да пускате програмите си е от менюто с проекти и сега ще разгледаме това меню подробно.

In this video tutorial we try to move forward with a LEGO Mindstorms Robot Inventor robot and we try to keep a straight line using the Motion Sensor. Without entering into the details of the programming we demonstrate what is the behavior of the robot when trying to keep a straight line with the Motion Sensor while we are participating in a FIRST LEGO League competition.

For making the diode blink we just use one of the examples available in the Arduino Software.

There is no block for programming the Ultrasonic Sensor in the retail version of the LEGO Mindstorms EV3 software. In this video tutorial we will show you how you can download & import such blocks in order to use the sensor.

On of the most precise ways to position on the FIRST LEGO League and other competition fields is to follow and align and in this tutorial we demonstrate exactly this - how consistent and reliable this method is to reach specific mission models. In this way you know that every time you will be at the right place, which is great.

Following the Advance Light/Color sensors calibration for a minimum value for a single sensor tutorial, in this one, we continue with finding the maximum value detected by a sensor and storing this value in an array.

Construct two legs for both sides of the robot. The task for this video is to attach this two legs on both sides and to build a system of gears and axles that power those legs.

We dispay the speed of rotation of the wheels on the brick screen. We use the math blocks to do a proper calculations from rotation to radians per second. Knowing the speed, the radiuses and the mass of the wheels we find energy in Joules accumulated in the construction.

Once you get used to it, it's easy. We promise! Here is the deal - we need 'Alternative models' and 'Alternative missions' to facilitate learning in a team of students or when you can not build the specific mission models.

In this 10 out of 10 tutorial we demonstrate the accuracy of the robot when we use acceleration in its movements. The robot has not sensors attached to it and it is not making use of it's internal sensors. The goal of the tutorial is to give you the understanding and to make a demonstration of how difficult it is to consistently reach a mission model without the use of sensor even when we use acceleration.

Какво е разрешено и какво не при построяване на робота без инструкции.

Как да използваме блокчето за дисплея, за да показваме изображения с EV3-G софтуера.

This is a remote control car. Have fun with it before disassembling it.

Нека направим програма, при която има движение напред и назад.

Има няколко неща, за които да внимавате, когато учениците работят с брика.
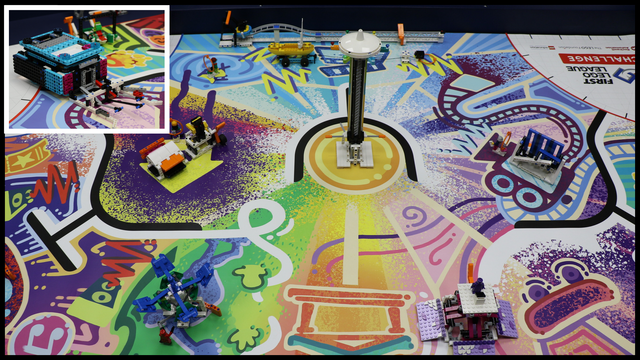
In this video tutorial, we demonstrate a full run of all missions without pausing the recording. The competition is the FIRST LEGO League 2023-2024 MASTERPIECE Challenge, and the robot is the Chain Monster - a LEGO Education SPIKE Prime robot.
These kinds of runs are extremely useful for team preparation right before the competition, as they help team members improve their accuracy, speed, and self-control.

With this 10 runs we demonstrate the consistency and reliability that could be achieved with a LEGO Education SPIKE Prime robot and a 2-states simple line following algorithm. It is not bad. Still there are some things you should consider when using this program and one of the things is the use of the timers

Обяснение и демонстрация на голямата задача за това занятие.

Developing a program for the Arduino is very easy. We need to do again three thigs:

This is a teacher's note about the math behind calculating gear ratios with for our lifting attachment. It math model we build in previous tutorials is not exactly correct and here is the explanation why.
