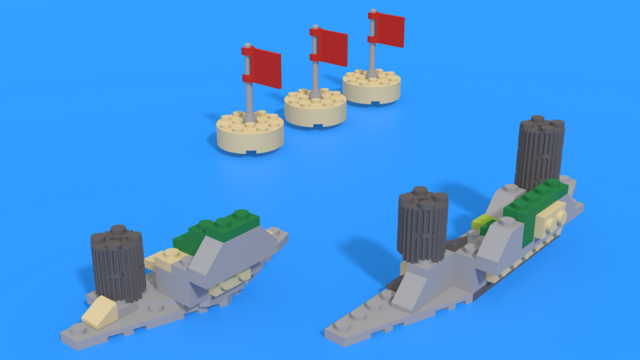
FLL 2022: Bag 8 - Instructions for M08 Watch Television Mission Model - FIRST LEGO League 2022-2023 SUPERPOWERED Challenge
3D building instructions for the watch television LEGO mission model from the FLL 2022 competition
- #1546
- 09 Aug 2022
3D building instructions for the watch television LEGO mission model from the FLL 2022 competition

Attachment for grabbing loops build from LEGO MINDSTORMS Robot Inventor 51515 set. We use this robot attachment to accomplish missions with loops at FIRST LEGO League. Well, we use the principle, that is what's important. Check out the attachment and the course to understand the principle of grabbing loops.

This is an pinless robot attachment designed for taking loops. It's built with LEGO MINDSTORMS Robot Inventor parts and it demonstrates how to collect a loop while moving with the robot. The attachment is designed for Luly, small LEGO Education SPIKE Prime competition robot with 3D building instructions. There are other attachments that are designed for taking a loop and locking it so that it does not fall, but they are more complex. Search for 'Carabiner' at FLLCasts.com

Zat is fun. Zat is great. It is a simple construction for a car with 4 large wheels. And who does not like cars with large wheels. Built from LEGO SPIKE Core set 45678 + LEGO SPIKE Expansion Set 45680 we had a lot of fun with it on Sunday. It was an idea of my wife and the kids took a lot of time putting things on in and moving it around. Just put things on it and play with it.

This is the attachment to accomplish Fll 2019 M08 mission with the Dominator robot. You can see how to attach the attachment to the robot in this tutorial.

Building instructions for the truck mission model. The model is used in the Road assistance mission of FLLCasts Off-season Challenge 2019.

Attachment for lifting object, especially hex balls if you have them from the Crossover competition.

It's the second version of VEX IQ Easy Bot. It's simple as the first one, but the motors are rotated.

Building instructions for a VEX IQ attachment for catching hex balls

Инструкции за четвъртия модул, версия 2, на робота Ugbroid - задни колела.


Building instructions for a LEGO Mindstorms EV3 Truck Robot Attachment for the FIRST LEGO League 2013 Nature's Fury robotics competition

- note that you could attach it to the brick both sides, depending on which technique you would like to test. Use the video as a reference.
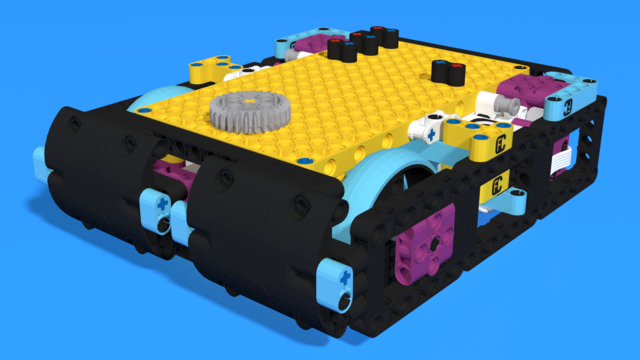
This is the beautiful version of the robot. :) It is more likely for having fun, than use it for competition. It have beautiful front that is not very useful for a competition, due to larger attachments, but it is a little bit more stable than the "uglier" and smaller version. :)
This robot is very low, relatively compact and very hard to control. To move as desired it must carry heavy attachment between its front tires. It also needs often clearing of its rear balls and the beads where they are positioned. Ones that is done the robot becomes pretty accurate. If you change the front tires with tires that have higher grip than the ones in the Spike set it becomes precious. Spike Prime Tires don't have grip but looks good. :)
It is ideal to learn how to control robots in real world applications where nature plays bad jokes on the engineers.
The two color sensors look up so it can see the attachment control parts, so it decides what part of the program to run. It have only one attachment motor with only 1 attachment element - 28 Teeth and 4 holes Gear.
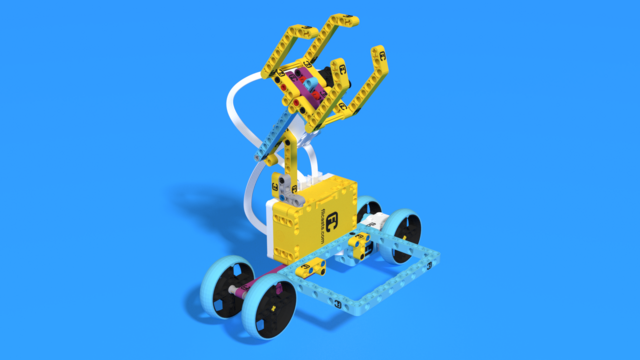
Минто (от англ. Mintonette) идва от името на една от първите версии на волейбол.
Този робот може да се движи само напред и назад, използвайки един среден мотор. Може да изстрелва топка, използвайки друг мотор и готин механизъм! Има мрежа, за да може да хваща топките на други роботи!
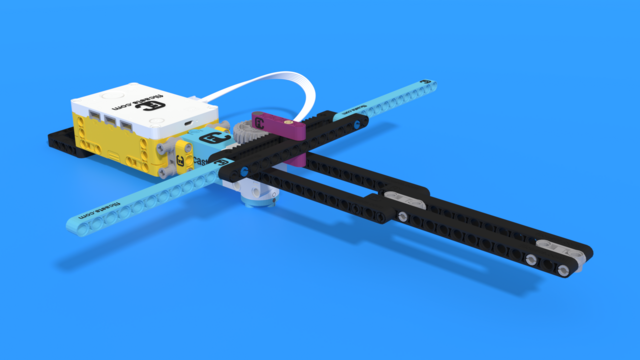
Пага идва от известния цигулар Николо Паганини.
Роботът е направен да прилича на цигулка. Той пуска по-висок тон колкото по-бързо се движи мотора. Да видим дали ще се справите да свирите на него!
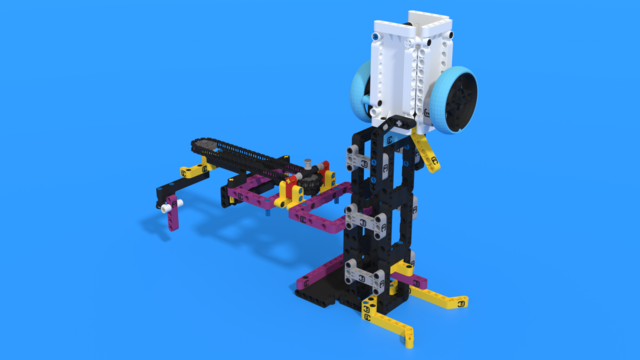
This attachment for the Nautiq robot is designed to accomplish M12 Feed the Whale in the FIRST LEGO League 2024‑2025 SUBMERGED competition. It demonstrates how to use mission models as part of a passive mechanical trigger and how to apply carabiner mechanisms for purposes other than locking.